Quick Answer
A harmonic drive gives 50:1–320:1 in one stage with near-zero backlash (≤1 arc-min), so choose it for robot joints and precision positioning. A planetary gear gives 3:1–100:1 per stage at 95–98% efficiency, so choose it for conveyors, CNC and heavy loads. Above 100:1, compare system efficiency, envelope and total cost, not ratio alone.- What Is a Harmonic Drive?
- What Is a Planetary Gear?
- How Harmonic Drives Work, Step by Step
- How Planetary Gears Work, Step by Step
- Harmonic Drive vs Planetary Gear: Feature Comparison Table
- Engineering Data: Efficiency, Temperature Limits & Torque Formulas
- Worked Example: Sizing a Robot-Joint Reducer
- Best Applications for Harmonic Drives
- Best Applications for Planetary Gears
- Selection Guide: Step-by-Step Process
- Common Engineering Mistakes
- Troubleshooting: Problem, Cause, Solution
- Why Choose Greensky Power?
- Related Resources
- References
- FAQ
What Is a Harmonic Drive?
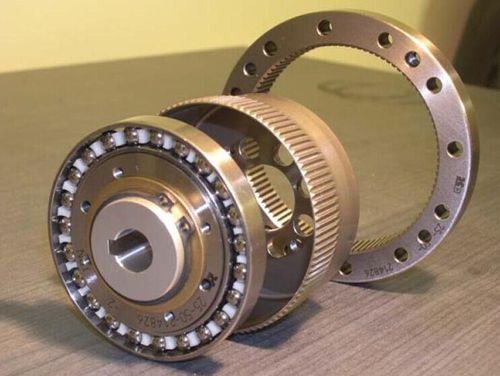
A harmonic drive, patented by American engineer C.W. Musser (U.S. Patent 2,906,143, granted 1959), is a precision gear mechanism that transmits motion through the controlled elastic deformation of a flexible component rather than through rigid tooth contact. The three core components are:
- Wave Generator (WG): an elliptical cam fitted with a thin-wall ball bearing that forces the flexspline into an elliptical shape.
- Flexspline (FS): a cup-shaped, thin-walled flexible gear with external teeth. It deforms elliptically and acts as the output element.
- Circular Spline (CS): a rigid internally-toothed ring that meshes with the flexspline at two zones 180° apart and is fixed to the housing.
In a standard double-wave design the flexspline carries two fewer teeth than the circular spline. As the wave generator rotates, the meshing zone travels around the circumference, so each full wave-generator revolution advances the flexspline by exactly two teeth in the opposite direction, producing reduction ratios from 50:1 to 320:1 in a single stage.
What Is a Planetary Gear?
A planetary gear (epicyclic gear) is a compact power-transmission system built from a central sun gear, several orbiting planet gears, an outer ring gear (internal teeth) and a planet carrier that carries the planet pins and serves as the output. The name follows the analogy of planets orbiting the sun.
Key characteristics:
- Single-stage ratios of 3:1 to 10:1; multi-stage (2–4 stages) ratios reach up to 10,000:1.
- Load is shared across 3–5 planet gears, distributing stress and raising torque density.
- Coaxial input–output alignment enables compact, in-line mounting.
- Rigid tooth meshing provides high stiffness and excellent shock-load resistance.
Planetary gear motors are specified under NEMA MG 1 (Motors and Generators) and, when sold in the U.S., must meet DOE 10 CFR Part 431 efficiency requirements as part of the motor–gearbox assembly.
How Harmonic Drives Work, Step by Step
- Input rotation: the motor drives the wave generator at high speed; the elliptical cam presses against the inner wall of the flexspline.
- Flexspline deformation: the flexspline is forced into an ellipse. Teeth at the major axis engage the circular spline; teeth at the minor axis fully disengage.
- Meshing-zone migration: with every 180° rotation of the wave generator, the meshing zone travels around the full circumference. Because the flexspline has two fewer teeth than the circular spline, each wave-generator revolution advances the flexspline by exactly two teeth in the opposite direction.
- Simultaneous multi-tooth contact: roughly 30% of teeth are engaged at any moment, spreading load across many contact points. This is why harmonic drives reach high torque density despite the thin flexspline wall.
- Output generation: the flexspline, fixed to the output flange, rotates slowly opposite to the wave generator, delivering reduced speed and amplified torque with virtually zero backlash.
The number of deformation cycles per wave-generator revolution is the wave number. The double-wave (two meshing zones) layout is most common, offering simpler structure and lower flexspline stress.
How Planetary Gears Work, Step by Step
- Input to sun gear: the motor shaft drives the central sun gear at full speed.
- Planet rotation: the sun gear meshes with 3–5 planet gears, spinning them on their own axes opposite to the sun.
- Planet revolution: because the planets also mesh with the fixed ring gear, they are forced to orbit the sun in the same direction as the sun.
- Carrier output: the planet carrier rotates at reduced speed, delivering the output torque.
With the ring gear fixed and the carrier as output, the single-stage ratio is:
i = 1 + Zr / Zs
where Zr = ring-gear teeth and Zs = sun-gear teeth. For higher ratios, the output carrier of stage 1 drives the sun of stage 2, and so on. Each stage typically achieves 3:1–10:1, losing 2–5% efficiency per stage.
Harmonic Drive vs Planetary Gear: Feature Comparison Table
| Parameter | Harmonic Drive (Strain-Wave Gear) | Planetary Gear |
|---|---|---|
| Transmission principle | Elastic deformation of flexspline | Rigid sun–planet–ring meshing |
| Core components | 3 (wave generator, flexspline, circular spline) | 4+ (sun, planets, ring, carrier) |
| Single-stage ratio | 50:1 – 320:1 | 3:1 – 10:1 |
| Multi-stage ratio | Up to 1,000:1 (rarely used) | Up to 10,000:1 (4-stage) |
| Backlash | ≤1 arc-min (near zero) | 1–6 arc-min (precision types: ≤1 arc-min) |
| Efficiency (single-stage) | 70% – 90% | 95% – 98% |
| Torque density | High (compact for ratio) | Very high (load sharing across planets) |
| Shock-load resistance | Moderate (flexspline fatigue risk) | Excellent (rigid meshing) |
| Rated-life L10 | 7,000 – 10,000 h at rated load | 20,000 – 50,000+ h at rated load |
| Weight (equivalent ratio) | Lighter | Heavier |
| Relative cost | 30% – 100% higher | Baseline (economical) |
| Typical max torque | Up to ~500 N·m (larger sizes) | Up to ~20,000 N·m (industrial sizes) |
| Reference basis | Manufacturer catalog (Harmonic Drive LLC, Leaderdrive, KOFON) | IEC 60034-1, NEMA MG 1 |
Engineering Data: Efficiency, Temperature Limits & Torque Formulas
1. Gearbox Efficiency Comparison
Efficiency data below are drawn from manufacturer datasheets; the motor efficiency class (IE1–IE5 per IEC 60034-30-1) compounds the gearbox effect at system level.
| Gearbox Type | Stages | Ratio | Max Efficiency | Backlash | Source |
|---|---|---|---|---|---|
| maxon GPX 22 (planetary) | 1 | 3.9:1 | 90% | 1.4° | maxon datasheet |
| maxon GPX 26 (planetary) | 1 | 3.9:1 | 90% | 0.75° | maxon datasheet |
| maxon GPX 37 LN (planetary) | 2 | 16:1 | 80% | 0.6° | maxon datasheet |
| maxon GPX 32 HP (planetary) | 3 | 103:1 | 65% | 0.9° | maxon datasheet |
| Siemens SIMOGEAR (helical) | 2 | 3.5–60:1 | ≥96% | — | Siemens catalog |
| Harmonic Drive SHD/CSF | 1 | 50–160:1 | 70–85% | ≤1 arc-min | Harmonic Drive LLC |
| Harmonic Drive CSG/SHG | 1 | 50–160:1 | 75–90% | ≤1 arc-min | Harmonic Drive LLC |
Planetary gears hold 90%+ efficiency in single stage and lose 5–10% per added stage. Harmonic drives reach 70–90%; they are lower at comparable ratios because energy is spent continuously flexing the flexspline. That flexing also generates heat, which becomes the limiting factor in continuous duty.
2. IEC 60034-1 Insulation Class Temperature Limits
The motor insulation class (IEC 60034-1) sets the maximum allowable operating temperature. Gearbox selection changes motor loading and therefore thermal behavior.
| Insulation Class | Max Temperature | Temp Rise Limit | Typical Application |
|---|---|---|---|
| Class A | 105°C | 60 K | Low-duty, largely obsolete |
| Class E | 120°C | 75 K | Light industrial |
| Class B | 130°C | 80 K | Standard industrial motors |
| Class F | 155°C | 100 K | Most industrial gear motors |
| Class H | 180°C | 125 K | High-temp, heavy-duty |
3. IEC 60034-30-1 Motor Efficiency Classes (IE1–IE5)
The motor paired with the gearbox must meet regional efficiency mandates. DOE’s 2023 direct final rule raises the U.S. minimum to IE4 (NEMA Premium 4) for 100–250 hp polyphase induction motors from June 1, 2027, projected to save U.S. businesses $8.8 billion and avoid 92 million metric tons of CO₂ over 30 years.
| IEC Class | NEMA Equivalent | Loss vs IE1 | Regulatory Status |
|---|---|---|---|
| IE1 | Standard Efficiency | Baseline | Phased out in most markets |
| IE2 | High Efficiency | ~10% less loss | Minimum in some regions |
| IE3 | Premium Efficiency | ~20% less loss | U.S. minimum since 2007; EU since 2021 |
| IE4 | Super-Premium | ~30% less loss | DOE mandatory June 2027 (100–250 hp) |
| IE5 | Ultra-Premium | ~40% less loss | Under development; not yet NEMA-defined |
4. Core Torque and Efficiency Formulas
Planetary single-stage ratio: i = 1 + Zr / Zs. For multi-stage: i_total = i₁ × i₂ × … × iₙ.
Harmonic ratio: i = Zfs / (Zcs − Zfs), where Zfs = flexspline teeth and Zcs = circular spline teeth. With Zcs − Zfs = 2, this simplifies to i = Zfs / 2; a 100-tooth flexspline gives 50:1.
Output torque (both types): T_out = T_in × i × η.
System efficiency (motor + gearbox): η_system = η_motor × η_gearbox. Example: IE4 motor (η = 94%) + 2-stage planetary (η = 90%) gives η_system = 0.94 × 0.90 = 84.6%. The IEA estimates that optimizing motor-driven system efficiency, including gearbox selection, could cut global industrial electricity use by 20–30%.
Harmonic-drive flexspline fatigue life (L10): Lh = Ln × (Tr / Tav)³ × (Nr / Nav), where Ln = rated life (7,000 or 10,000 h per catalog), Tr = rated torque, Tav = average load torque, Nr = rated input speed, Nav = average input speed. Doubling load torque cuts life by a factor of 8.
SKF bearing life (L10h) for planetary planet bearings: L10h = (1,000,000 / 60n) × (C / P)³, where C = basic dynamic load rating, P = equivalent dynamic load, n = speed (rpm).
NEMA MG 1 service factor: SF = T_peak / T_rated, typically 1.0–1.15 for standard motors, up to 1.25 for special designs. Size the gearbox for motor peak torque multiplied by the service factor.
5. Harmonic Drive Torque Limits
Per Harmonic Drive LLC engineering data, the flexspline, the part under repeated elastic deformation, sets torque capacity:
- Rated torque: continuous load at rated speed for rated flexspline fatigue life.
- Repeated peak torque: allowable cyclic overload within the flexspline fatigue limit.
- Momentary peak (impact) torque: must stay under the allowable limit; maximum bending cycles
1.0 × 10⁴, fromN = 1.0 × 10⁴ / (2 × n/60 × t). - Ratcheting torque: 8–9× rated. Teeth disengage, concentricity is lost, wear accelerates.
- Buckling torque: 16–17× rated. Plastic deformation of the flexspline, catastrophic failure.
Worked Example: Sizing a Robot-Joint Reducer
A 6-axis robot joint needs an output speed of 30 rpm and continuous output torque of 110 N·m (peak 330 N·m) in continuous duty (S1). The servo motor is rated 3,000 rpm, 1.5 N·m (peak 4.5 N·m).
Step 1, required ratio: i_req = n_motor / n_output = 3000 / 30 = 100:1.
Step 2, harmonic-drive option (single-stage 100:1, η = 0.85):
– Continuous: T_out = 1.5 × 100 × 0.85 = 127.5 N·m, which exceeds 110 N·m.
– Peak: 4.5 × 100 × 0.85 = 382.5 N·m, which exceeds 330 N·m.
– Backlash ≤1 arc-min meets joint repeatability.
– Thermal check: continuous S1 duty requires a 20–30% derate, so 127.5 × 0.75 ≈ 95.6 N·m, below the 110 N·m requirement. This is marginal and needs forced cooling or the next size up.
Step 3, precision planetary option (3-stage to 100:1, η = 0.95³ = 0.857):
– Continuous: 1.5 × 100 × 0.857 = 128.6 N·m, which exceeds 110 N·m.
– Peak: 4.5 × 100 × 0.857 = 385.6 N·m, which exceeds 330 N·m.
– Backlash: a precision type (≤1–3 arc-min) is required for joint repeatability.
– Thermal: rigid meshing runs cooler, better for continuous duty.
Step 4, decision: both meet torque. The harmonic drive wins on envelope and backlash; the planetary wins on thermal margin and cost. Recommendation: specify the harmonic drive only if heat is managed (forced air or one size larger); otherwise choose a precision planetary.
| Option | Ratio | η | T_out (cont.) | T_out (peak) | Backlash | Thermal (S1) |
|---|---|---|---|---|---|---|
| Harmonic, 1-stage | 100:1 | 85% | 127.5 N·m | 382.5 N·m | ≤1 arc-min | Marginal, derate |
| Precision planetary, 3-stage | 100:1 | 85.7% | 128.6 N·m | 385.6 N·m | ≤1–3 arc-min | Strong |
Best Applications for Harmonic Drives
| Application | Why Harmonic Drive? | Typical Ratio |
|---|---|---|
| Industrial robot joints (6-axis arms) | Zero backlash for repeatability; compact joint envelope; single-stage ratio avoids backlash accumulation | 50:1 – 160:1 |
| Collaborative robots (cobots) | Lightweight; smooth, human-safe motion; high torsional stiffness for torque sensing | 100:1 – 160:1 |
| Semiconductor equipment | Sub-arc-min accuracy for wafer alignment; low vibration for cleanrooms | 80:1 – 120:1 |
| Aerospace actuation | High reduction in minimal weight/space; qualified to DO-160G and AS9100D | 100:1 – 320:1 |
| Medical/surgical robotics | Precision positioning; zero backlash for haptics; compact end-effectors | 50:1 – 100:1 |
Best Applications for Planetary Gears
| Application | Why Planetary Gear? | Typical Ratio |
|---|---|---|
| Industrial automation (conveyors, indexers) | High torque; shock resistance; cost-effective continuous duty | 3:1 – 100:1 |
| Servo-driven CNC machinery | Low-backlash precision types; high stiffness; high input speed | 5:1 – 40:1 |
| AGV and mobile-robot drivetrains | Compact in-line; high efficiency extends battery life; absorbs accel/decel shocks | 10:1 – 50:1 |
| Packaging and filling machinery | High cycle durability; multi-stage ratios for synchronized axes; easy maintenance | 10:1 – 100:1 |
| Heavy-duty handling (cranes, hoists) | Very high torque (up to 20,000 N·m); robust build; long life | 20:1 – 300:1 |
Selection Guide: Step-by-Step Process
Step 1: Define Application Requirements
Document required output speed, continuous torque, peak torque, duty cycle (IEC 60034-1 S1–S10), positioning accuracy, backlash tolerance, ambient temperature and available envelope. Decide whether the application is precision-focused (favouring harmonic drive) or power-focused (favouring planetary gear).
Step 2: Calculate Required Gear Ratio
Using i = n_motor / n_output, determine the reduction. If i ≤ 10:1, a single-stage planetary is optimal. If 10:1 < i ≤ 100:1, compare 2–3 stage planetary against a single-stage harmonic drive. If i > 100:1, the candidates are harmonic drives or 3–4 stage planetary gears.
Step 3: Evaluate Backlash Requirements
For robotics, semiconductor and precision positioning needing ≤1 arc-min, harmonic drives are the default. For general automation with 3–6 arc-min tolerance, precision planetary gears offer better cost-efficiency. For non-positioning duties (conveyors, pumps), standard planetary gears with 6+ arc-min backlash suffice.
Step 4: Torque and Life Verification
For harmonic drives, apply Lh = Ln × (Tr/Tav)³ × (Nr/Nav) to confirm L10 life. Remember the cubic relation: a 50% torque overload cuts life by 87.5%. For planetary gears, verify planet-bearing life with L10h = (1,000,000/60n) × (C/P)³ and confirm rated torque exceeds application peak torque multiplied by the NEMA MG 1 service factor.
Step 5: Efficiency and Thermal Analysis
Calculate η_system = η_motor × η_gearbox and compare lifetime energy cost. The IEA reports energy is 95–97% of a motor system’s total lifecycle cost. For continuous duty, confirm gearbox heat dissipation keeps winding temperature within the IEC 60034-1 insulation limit (e.g., 155°C for Class F). Harmonic drives often need derating for continuous operation because the flexspline generates heat.
Step 6: Cost and Total Cost of Ownership (TCO) Analysis
Compare purchase price, maintenance interval, lubrication and replacement cost. Harmonic drives typically cost 30–100% more than equivalent planetary gears but may be justified by precision. Use TCO = Purchase + Energy + Maintenance + Downtime. The DOE projects that moving to IE4 motor efficiency alone saves $8.8 billion over 30 years, and gearbox efficiency compounds the same way.
Step 7: Standards Compliance Verification
Confirm the motor–gearbox assembly complies with IEC 60034-1 (rating and performance), IEC 60034-30-1 (efficiency class), NEMA MG 1 (U.S. motor and generator specification), DOE 10 CFR Part 431 (U.S. efficiency mandate) and IEC 60034-5 (IP protection). For aerospace, verify DO-160G and AS9100D.
Step 8: Prototype Testing and Validation
Order samples and run accelerated life testing under representative load cycles. Measure backlash, efficiency, temperature rise and noise. For harmonic drives, monitor flexspline tooth-root stress, the predominant fatigue-crack site per IEEE-indexed research (DOI: 10.19287/j.mtmt.1005-2402.2023.08.011). For planetary gears, verify bearing temperature and tooth contact pattern.
Common Engineering Mistakes
Mistake 1: Overloading Harmonic Drives Beyond Rated Torque
Sizing a harmonic drive on average torque while ignoring peaks is the most common failure. Because life scales with the cube of torque ratio, a 1.5× overload cuts L10 life by about 70%. Always size for peak torque and apply the fatigue formula with real load-spectrum data. If peak torque exceeds 2× rated, choose a larger size or switch to planetary.
Mistake 2: Using Harmonic Drives in High-Impact Applications
Installing harmonic drives in palletizers, stamping presses or equipment with frequent emergency stops accelerates flexspline fatigue at the tooth root. For frequent shock loads, select planetary gears with their rigid load-sharing architecture. The NEMA MG 1 service factor (1.0–1.25) adds margin for shock.
Mistake 3: Ignoring Efficiency Loss in Multi-Stage Planetary Gears
A 4-stage planetary at 1,000:1 can drop to ~66% efficiency (e.g., maxon GPX 22, 4-stage). That 34% loss becomes heat, forcing larger motors and cooling. For ratios above 100:1, compare 4-stage planetary (η ≈ 66%) against single-stage harmonic drive (η ≈ 80%) on system efficiency.
Mistake 4: Selecting Planetary Gears for Ultra-Precision Positioning
Standard planetary gears (3–6 arc-min) in wafer alignment or surgical robotics fall short of sub-arc-min needs; even “low-backlash” types (1–3 arc-min) can grow backlash after wear-in. For ≤1 arc-min, harmonic drives give inherently zero backlash through continuous flexspline–circular-spline preload. Ultra-precision planetary types (≤1 arc-min) exist but approach harmonic-drive cost with inferior repeatability.
Mistake 5: Neglecting Thermal Management for Harmonic Drives
Running harmonic drives at rated torque and high speed in continuous (S1) duty without checking temperature rise is risky; a 10°C rise can halve flexspline fatigue life. Derate harmonic torque by 20–30% for continuous duty, keep flexspline temperature within the lubricant limit (typically ≤80°C for standard lubricants) and consider synthetics for high temperature.
Mistake 6: Mismatching Motor Efficiency Class with Gearbox Type
Pairing an IE4 motor (94%) with a low-efficiency 4-stage planetary (66%) yields only 62% system efficiency, so the IE4 investment is wasted by gearbox losses. Per DOE 10 CFR Part 431, IE4 becomes mandatory for 100–250 hp from June 2027; pair it with high-efficiency gearboxes (≥95% per stage) to realize the savings. The IEA estimates 20–30% industrial energy savings from system-level optimization.
Troubleshooting: Problem, Cause, Solution
| Problem | Likely Cause | Solution |
|---|---|---|
| Harmonic flexspline cracking at tooth root | Repeated peak torque beyond fatigue limit; impacts above momentary rating | Reduce peak load; choose larger unit; switch to planetary for shock; verify with Lh = Ln × (Tr/Tav)³ × (Nr/Nav) |
| Harmonic ratcheting (teeth skipping) | Output torque over 8–9× rated; insufficient housing stiffness | Reduce load; stiffen housing; verify ratcheting torque; replace after any ratcheting event |
| Planetary backlash grows after service | Bearing/gear wear from poor lubrication; carrier deformation | Replace bearings; verify lube interval; check tooth contact; predict replacement with SKF L10h |
| Planetary overheating | Overload; low lube; input speed over rated; blocked ventilation | Check load vs rated; verify oil level/viscosity; lower input speed; clean fins; monitor per Class F (155°C) |
| Harmonic efficiency drops over time | Lubricant breakdown; flexspline micro-cracks; WG bearing wear | Relube per schedule; inspect flexspline; replace WG bearing; log efficiency trend |
| Planetary noise/vibration rises | Gear pitting; planet-bearing damage; misalignment | Vibration analysis; replace gears/bearings; verify coaxial alignment; balance coupling |
| Harmonic output-position drift | Circular-spline wear; flexspline asymmetry; thermal dimensional change | Re-calibrate feedback; inspect engagement; stabilize temperature; add thermal comp |
| Motor trips on overload with gearbox | Gearbox η lower than assumed; start torque over breakdown; wrong ratio | Recompute η_system; check motor torque-speed vs start torque; verify NEMA SF; size motor for real loss |
Why Choose Greensky Power?
Greensky Power Co., Ltd. is a China-based manufacturer specializing in precision gear-motor solutions for global B2B markets. Our capabilities span both planetary gear motors and harmonic-drive assemblies, so recommendations are application-optimized rather than single-technology biased.
- Vertical integration: motor winding, gear machining, assembly and 100% load testing under one roof, giving consistent quality from raw material to finished product.
- Engineering-driven selection: our team applies IEC 60034-30-1 efficiency analysis, NEMA MG 1 service-factor calculations and SKF bearing-life verification to every recommendation. We engineer solutions, not just sell parts.
- Standards compliance: all gear motors meet IEC 60034-1 performance ratings and are available with IE3/IE4 classes for DOE 10 CFR Part 431 compliance.
- Global presence: we exhibit at Hannover Messe, Canton Fair and Automate, keeping direct technical dialogue with customers worldwide.
- Custom engineering: whether your application needs the zero-backlash precision of a harmonic drive or the high-torque durability of a planetary gearbox, our R&D team delivers custom ratios, mounting and motor integration within 4–6 weeks.
Learn more about our manufacturing capabilities, or explore our High Precision Planetary Gearboxes: Backlash, Stiffness and Real Positioning Accuracy, Planetary Gear Motor Applications, Benefits of a High Torque Brushless DC Motor, Custom Brushless DC Motors for Your Application, What Is a DC Motor? Types, Working Principle & Engineering Formulas, Top 10 Electric Motor Manufacturers in the World and Top 10 Popular BLDC Motor Applications & Markets. For technical consultation on harmonic drive vs planetary selection, contact our engineering team. Get Free Quote
Related Resources
- High Precision Planetary Gearboxes: Backlash, Stiffness and Real Positioning Accuracy
- Planetary Gear Motor Applications
- Benefits of a High Torque Brushless DC Motor
- Custom Brushless DC Motors for Your Application
- What Is a DC Motor? Types, Working Principle & Engineering Formulas
- Top 10 Electric Motor Manufacturers in the World
- Top 10 Popular BLDC Motor Applications & Markets
References
- IEC 60034-1:2022, “Rotating electrical machines — Part 1: Rating and performance,” International Electrotechnical Commission. https://webstore.iec.ch/publication/64888
- IEC 60034-30-1:2014, “Rotating electrical machines — Part 30-1: Efficiency classes of line operated AC motors,” International Electrotechnical Commission. https://webstore.iec.ch/publication/67563
- NEMA MG 1-2021, “Motors and Generators,” National Electrical Manufacturers Association. https://www.nema.org/standards/view/Motors-and-Generators
- U.S. DOE, “Energy Conservation Program: Energy Conservation Standards for Electric Motors,” 10 CFR Part 431. https://www.ecfr.gov/current/title-10/chapter-II/subchapter-D/part-431
- International Energy Agency (IEA), “Energy Efficiency 2024 — Motor Systems Analysis.” https://www.iea.org/reports/energy-efficiency-2024
- SKF Group, “Bearing Life Calculation — L10 Methodology for Gear Applications.” https://www.skf.com/group/technical-insights/bearings
- Siemens AG, “SIMOGEAR Geared Motors — Technical Catalog.” https://assets.new.siemens.com/siemens/assets/api/uuid:bc14c4a0-65b6-4058-a9f7-d29284b065b1/dimc-b10068-00-7600simogearexplosion-protectedgearedmotorsen-72.pdf
- Harmonic Drive LLC, “Engineering Data — Flexspline Fatigue Life, Torque Limits, and Selection (SHD/CSF/CSG).” https://www.harmonicdrive.net/_hd/content/documents/FR_Component.pdf
- Cheng, Y.-H. & Chen, Y.-C. (2022), “Design, analysis, and optimization of a strain wave gear with a novel tooth profile,” Mechanism and Machine Theory, Vol. 175. DOI: 10.1016/j.mechmachtheory.2022.104953
- Yu, X. et al. (2023), “Stress analysis and fatigue strength evaluation of flexsplines of industrial robot harmonic reducer,” Manufacturing Technology & Machine Tool. DOI: 10.19287/j.mtmt.1005-2402.2023.08.011
- maxon, “GPX Gear Program — Planetary Gearheads Datasheet.” https://www.maxon.com
- U.S. DOE (2023), “Direct Final Rule: Energy Conservation Standards for Electric Motors (100–250 hp IE4 from June 1, 2027).” https://www.energy.gov/
FAQ
Frequently Asked Questions
Which is more efficient: harmonic drive or planetary gear?
Planetary gears are generally more efficient. Single-stage planetary reaches 95–98%; single-stage harmonic drives reach 70–90%. The gap widens at high ratios because planetary needs multiple stages (each losing 2–5%), while harmonic stays single-stage but loses energy to continuous flexspline deformation. Per IEA/IEC 60034-30-1, an IE4 motor with a 96%-efficient planetary gearbox gives 90.2% system efficiency, versus 79.9% with an 85%-efficient harmonic drive.
Can a harmonic drive replace a planetary gear?
Only in specific cases. Harmonic drives suit high single-stage ratios (50:1–320:1), zero backlash and compact size, which is typical in robotics and precision positioning. They are unsuitable for high-torque, high-shock or 24/7 industrial duty where planetary gears excel. Harmonic-drive L10 life (7,000–10,000 h) is far shorter than planetary (20,000+ h), making them weaker for continuous operation.
What is the backlash difference between harmonic drive and planetary gear?
Harmonic drives have virtually zero backlash (≤1 arc-min) because the flexspline teeth stay preloaded against the circular spline. Standard planetary gears show 3–6 arc-min; precision types reach 1–3 arc-min; ultra-precision types hit ≤1 arc-min but approach harmonic-drive cost. For backlash-critical positioning (robotics, CNC, semiconductor), harmonic drives are the default.
How long do harmonic drives last compared to planetary gears?
Per Harmonic Drive LLC data, harmonic-drive L10 (90% survival) is 7,000 h for standard series (CSF, CSD, SHF, SHD) and 10,000 h for high-torque series (CSG, SHG) at rated load; L50 is 35,000–50,000 h. Planetary gears typically reach 20,000–50,000+ h L10, with SKF bearing life as the limiting factor. The cubic torque-life relation makes harmonic overloading far more damaging.
Are harmonic drives more expensive than planetary gears?
Yes, typically 30–100% more for equivalent torque, reflecting precision flexspline manufacturing, the flexible wave-generator bearing and lower volumes. But above 100:1 a single-stage harmonic drive can beat a 3–4 stage planetary on total system cost once mounting hardware and motor sizing are included.
What standards apply to harmonic drives and planetary gears?
Planetary gear motors follow IEC 60034-1, IEC 60034-30-1 (IE1–IE5), NEMA MG 1 and DOE 10 CFR Part 431 (IE4 from June 2027). Harmonic drives are governed mainly by manufacturer specs (Harmonic Drive LLC, Leaderdrive, KOFON) rather than international efficiency standards, though the motor portion must still meet IEC/NEMA/DOE rules. The IEA notes motor-driven systems are ~53% of global electricity use, so efficiency compliance is a system-level concern.